PhD student · EECS · UC Berkeley
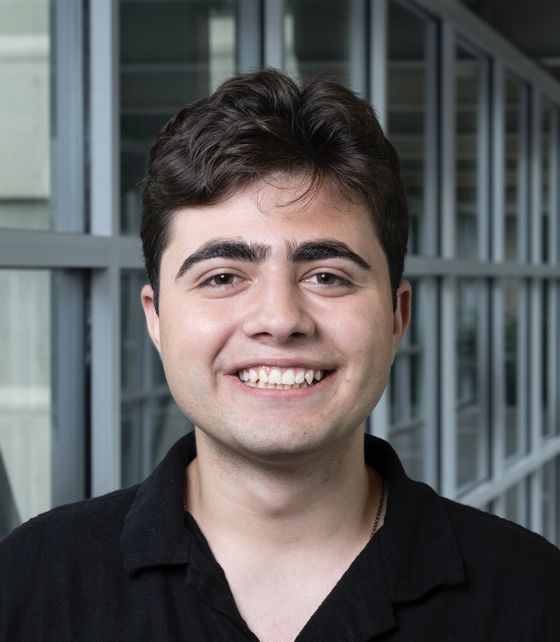
Narek Harutyunyan
I work on robot learning: policies that transfer across robot bodies, controllers whose stability can be certified, and the sim-to-real pipelines that carry both onto hardware.
01
About
I'm a PhD student in Electrical Engineering and Computer Sciences at UC Berkeley, supported by the Berkeley Fellowship. I work where robot learning meets control: cross-embodiment visuomotor policies, reinforcement learning with certified stability, and sim-to-real transfer for legged, aerial, and mobile manipulators.
I earned my B.S. in Computer Engineering at Brown University, where I spent three years in Nora Ayanian's ACT Lab working on multi-robot systems and quadrotor swarms. I've twice been a Robotics Institute Summer Scholar at Carnegie Mellon, in Sebastian Scherer's AirLab and Guanya Shi's LeCAR Lab, and a SURF fellow at Caltech in Soon-Jo Chung's Aerospace Robotics and Control Lab.
- Now
- Ph.D., Electrical Engineering and Computer SciencesUC Berkeley · 2026 –
- Before
- B.S., Computer EngineeringBrown University · 2022 – 2026
- Interests
- Robot learning, whole-body control, sim-to-real transfer, multi-robot systems
02
Research
-
Carnegie Mellon University · LeCAR Lab
Cross-embodiment visuomotor policies for wheeled, legged, and aerial manipulators.
May 2026 – Present
-
Caltech · Aerospace Robotics and Control Lab
ContractionPPO: certifiably stable RL controllers, deployed on the Unitree Go1 and Booster T1.
May – Sep 2025
-
Carnegie Mellon University · AirLab
MapExRL: long-horizon indoor exploration with reinforcement learning and predicted maps.
May 2024 – Jul 2025
-

Brown University · ACT Lab
Quadrotor swarms: multi-agent RL, formation flight, and downwash aerodynamics.
May 2023 – May 2026
03
Publications
-
IEEE RA-L · 2026Co-first author
ContractionPPO: Certified Reinforcement Learning via Differentiable Contraction Layers
IEEE Robotics and Automation Letters (RA-L), 2026
-
ICAR · 2025Co-first author
MapExRL: Human-Inspired Indoor Exploration with Predicted Environment Context and Reinforcement Learning
IEEE International Conference on Advanced Robotics (ICAR), 2025. Also presented at the ICRA 2025 Workshop on Structured Learning for Efficient, Reliable, and Transparent Robots.
-
ICRA · 2025
MapEx: Indoor Structure Exploration with Probabilistic Information Gain from Global Map Predictions
IEEE International Conference on Robotics and Automation (ICRA), 2025
-
AIAA Aviation · 2024
Downwash Dynamics: Impact of Quadrotor Separation on Forces, Moments, and Velocities for Dense Formation Flight
AIAA Aviation Forum and ASCEND, 2024
Posters & projects
-
Brown DL Day · 2024TAs' Choice Award
RoboChaser
An iRobot Create 3 that follows a custom car. Brown University Deep Learning Day, 2024.
-
Yale NERC · 2023
Advancements in Multi-Robot Systems
Northeast Robotics Colloquium (NERC), Yale University, 2023
04
Robots
Footage from the labs I've worked in: swarms, quadrupeds, humanoids, and a few drones that paint.
05
Teaching
-
Spring 2024
Fall 2024
Spring 2026CSCI 1952Z: Robots as a Medium · Head TA
Creating art with teams of robots; weekly labs for 75+ students.
-
Fall 2025
CSCI 1470: Deep Learning · Teaching Assistant
Labs, workshops, and final-project mentoring for 120+ students.
-
Fall 2023
ENGN 0032: Introduction to Engineering · Teaching Assistant
Prototyping, CAD, and electronics workshops for 100+ students.
06
Honors
-
2026
Berkeley Fellowship for Graduate Study — one of three EECS recipients
-
2024, 2026
Robotics Institute Summer Scholar — Carnegie Mellon University
-
2025
Summer Undergraduate Research Fellowship — Caltech
-
2024
TAs' Choice Award, Deep Learning Day — Brown University
-
2024 –
Tau Beta Pi Engineering Honor Society
-
2023, 2024
Undergraduate Teaching and Research Awards — Brown University
-
2023, 2024
Huys Foundation STEM Scholar — about 5% selection rate
Service
-
2026
Reviewer, IEEE Robotics and Automation Letters (RA-L)
-
2025
Reviewer, International Conference on Advanced Robotics (ICAR)
07
Contact
-
Email
-
Scholar
-
LinkedIn
-
CV
-
Based in
Berkeley, California · EECS, UC Berkeley